|
I am currently a third-year Ph.D. student at the Institute of Automation, Chinese Academy of Sciences (CASIA). I conduct my research within the group of Prof. Dongbin Zhao, under the supervision of Prof. Qichao Zhang. My research interests primarily focus on Embodied AI and Autonomous Driving. I have maintained close collaborations with industry partners, including Horizon Robotics and Anyverse Robotics. At Horizon Robotics, I was very honored to collaborate with Dr. Wei Yin. I also had the great honor of collaborating with Prof. Xiaoxiao Long from Nanjing University. Email / CV / Google Scholar / GitHub / |
|
|
My long-term goal is to build Physical AI that understands the physical world. Such intelligence should integrate visual and tactile inputs to comprehend properties like distance and mass, enabling reasonable control and planning. I am open to any related research directions and currently focus on Embodied AI and Autonomous Driving. My main interests include World Models, Structural Modeling, and Visuotactile Fusion. |
|
|
|
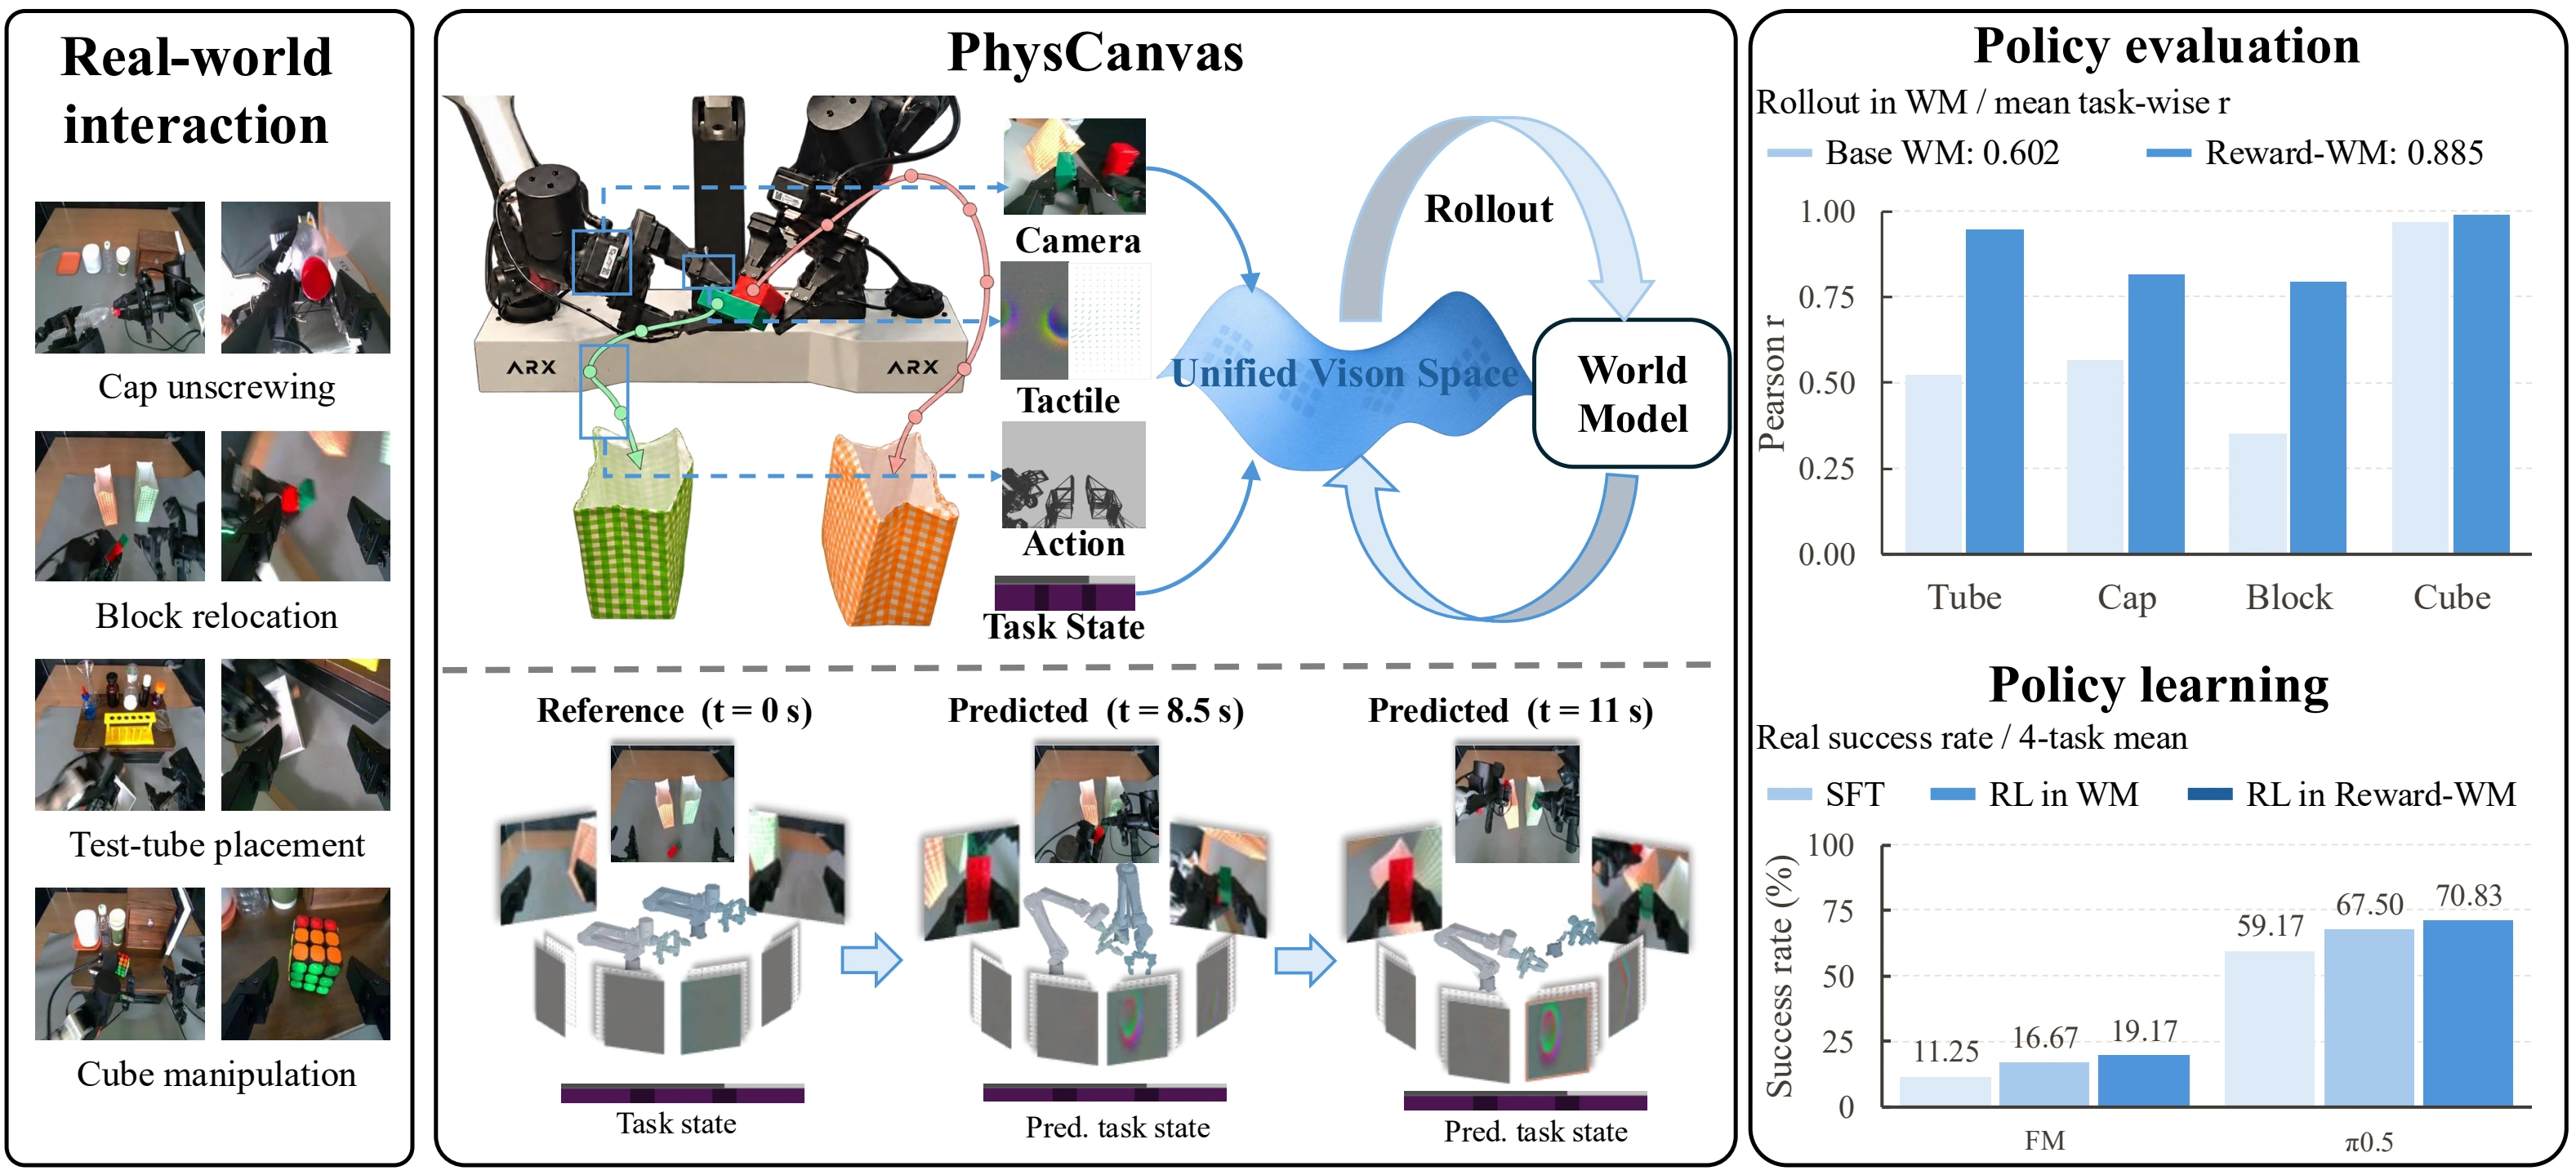
Zebin Xing, Yuhang Zheng, Yupeng Zheng, Yichen Zhang, Zichen Li, Shangqing Zhou, Yujie Zang, Yuchen Liu, Zhongpu Xia, Haoran Li, Qichao Zhang arXiv, 2026 [arXiv] [Homepage] [Code] 
To the best of our knowledge, PhysCanvas is the first vision-tactile world model to support reinforcement learning (RL) post-training of robot policies. Evaluated with ACT, Flow Matching, VLA (Pi0.5), and WAM (Phoenix-MWA), it improves policy performance by approximately 10% on average. |
|
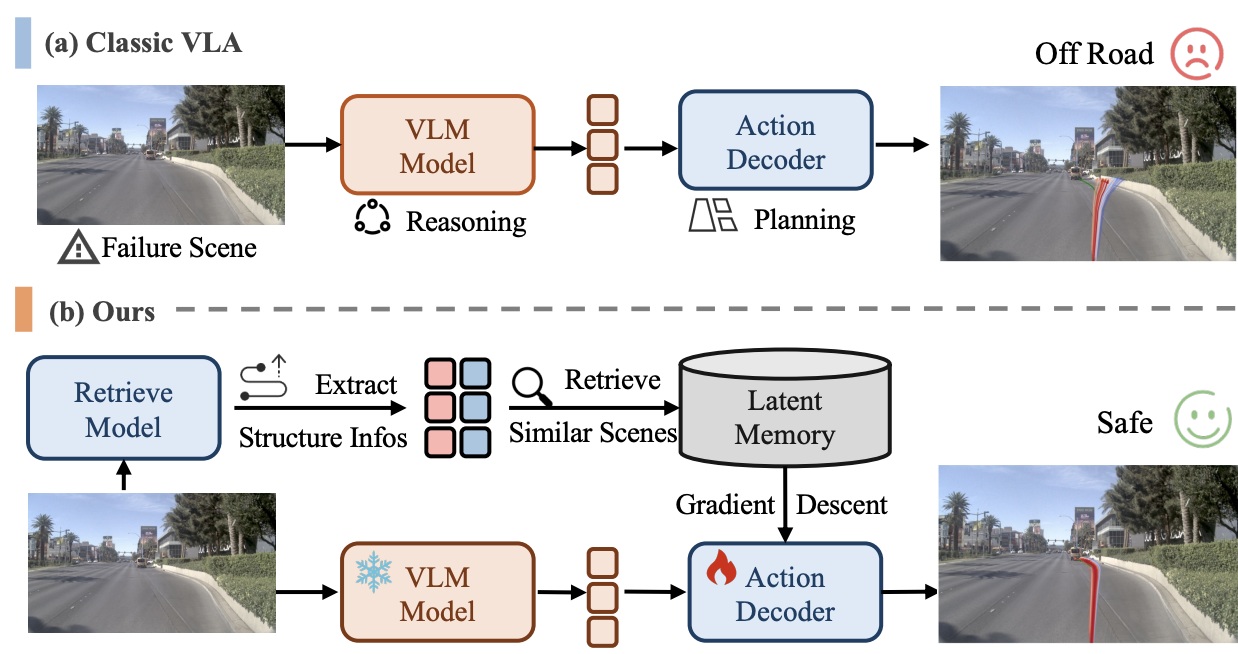
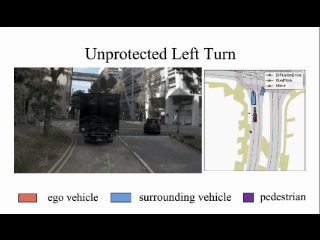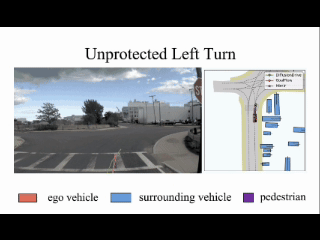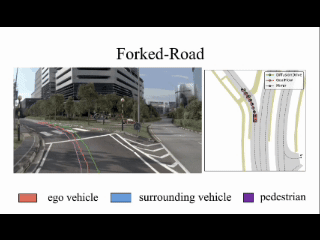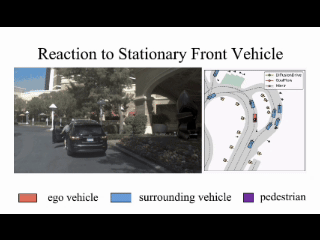
Zebin Xing, Yupeng Zheng, Qiang Chen, Linbo Wang, Yichen Zhang, Pengxuan Yang, Junli Wang, Deheng Qian, Xiaoqing Ye, Junyu Han, Yifeng Pan, Qichao Zhang†, Dongbin Zhao ACM MM, 2026 [arXiv] [Code] 
A failure-aware memory augmentation framework that introduces structural retrieval into VLA driving. |
|
Zebin Xing, Yupeng Zheng, Qichao Zhang†, Zhixing Ding, Pengxuan Yang, Songen Gu, Zhongpu Xia, Dongbin Zhao RA-L, 2025 [arXiv] [Code] 
A hierarchical dual-system framework that propagates goal uncertainty through Laplace distribution to generate robust trajectories with accelerated multi-rate guidance. |
|
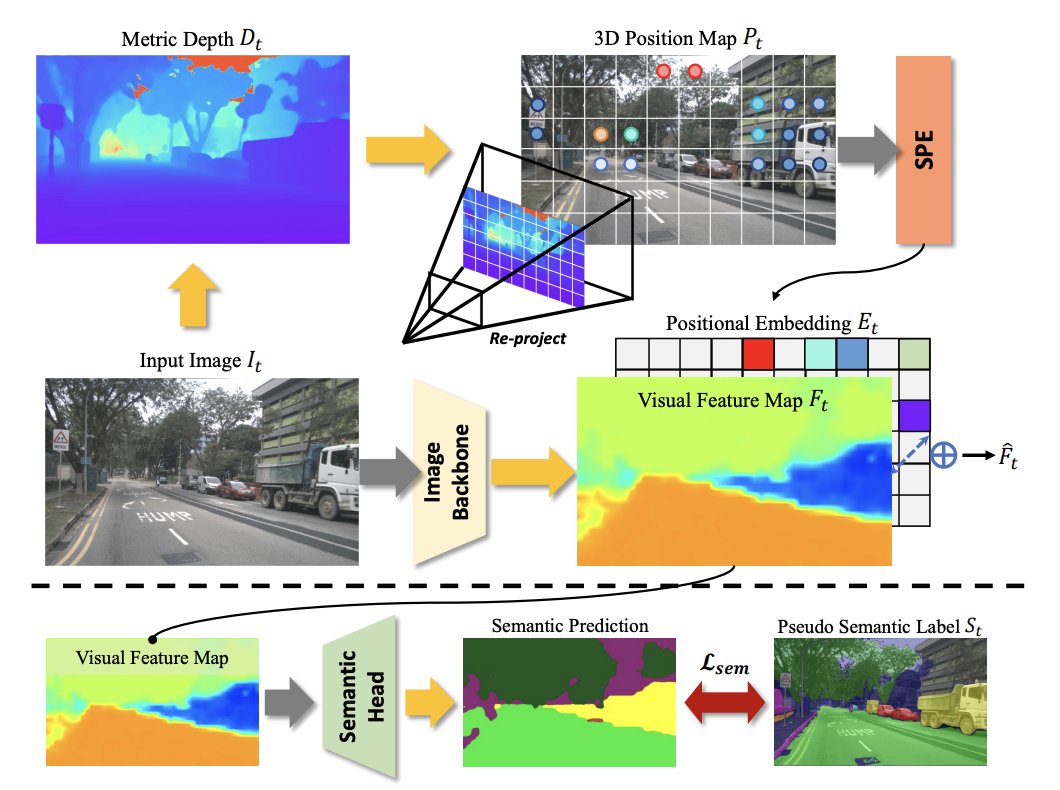
Yupeng Zheng, Pengxuan Yang, Zebin Xing, Qichao Zhang†, Yuhang Zheng, Yinfeng Gao, Pengfei Li, Teng Zhang, Zhongpu Xia, Peng Jia, Dongbin Zhao ICCV, 2025 [arXiv] [Code] 
An intention-aware physical latent world model that enables perception annotation-free end-to-end driving through vision foundation models and self-supervised world modeling. |
|
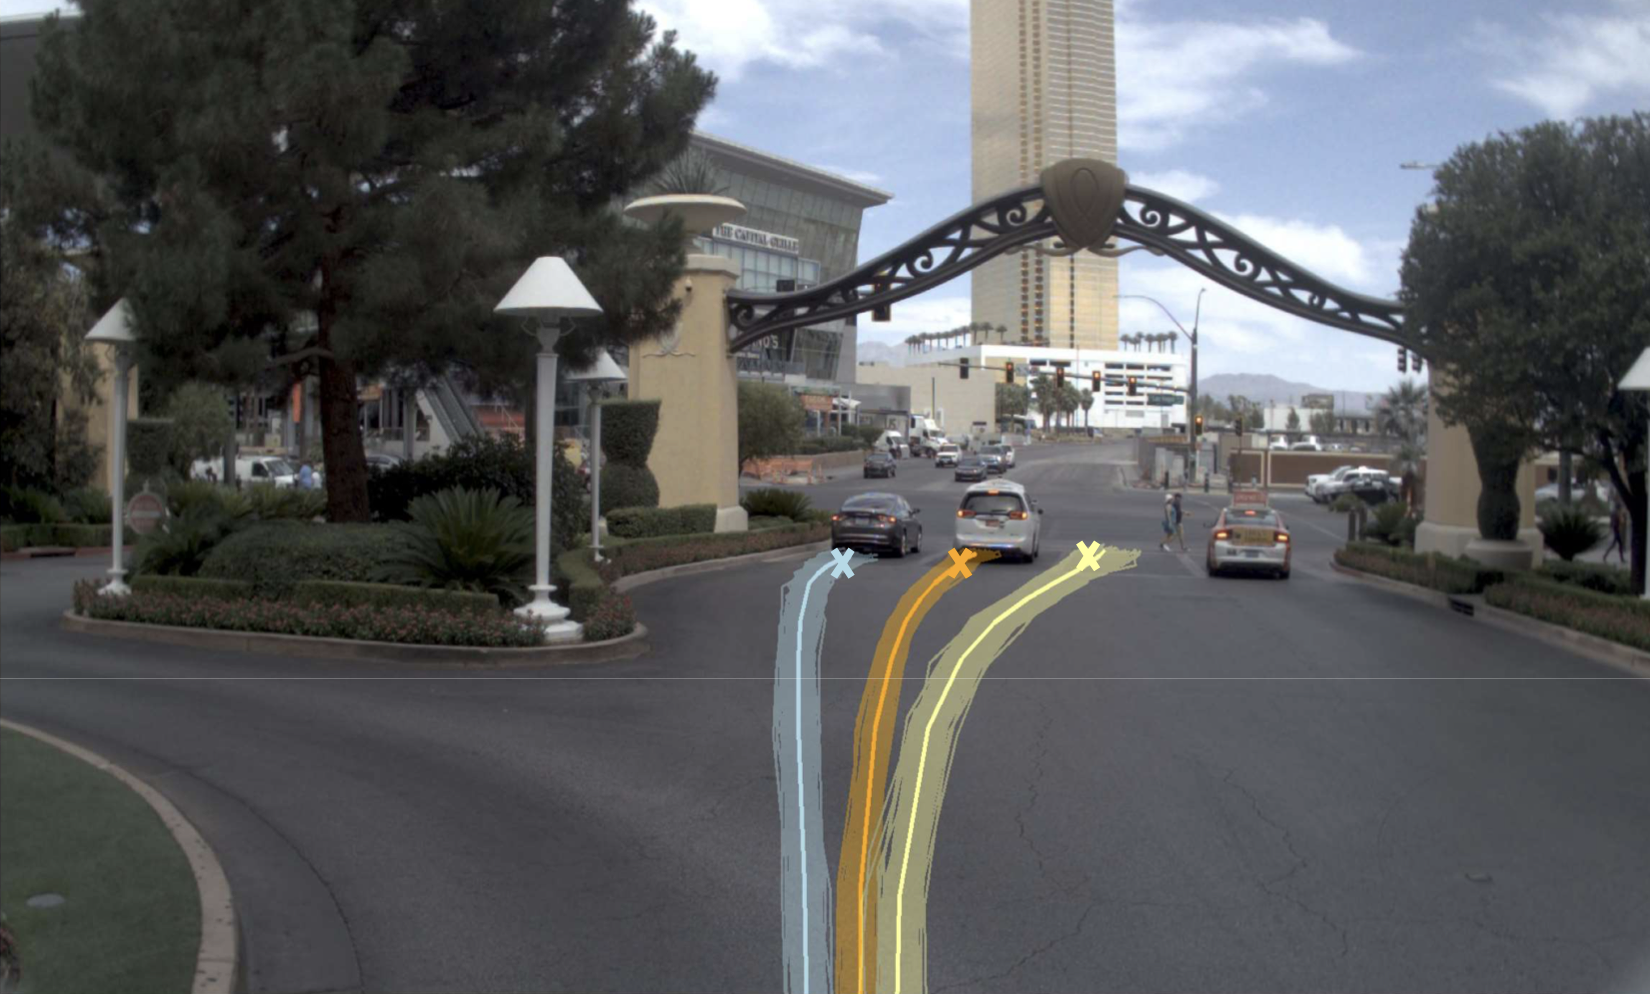
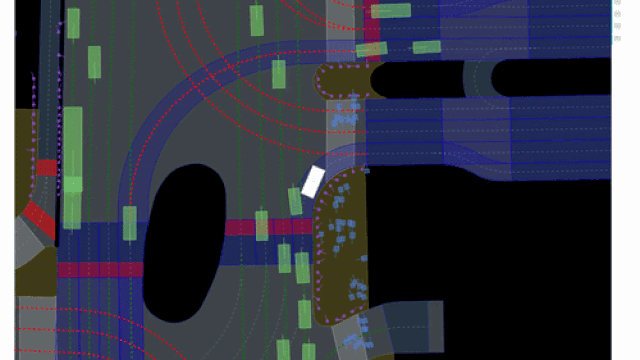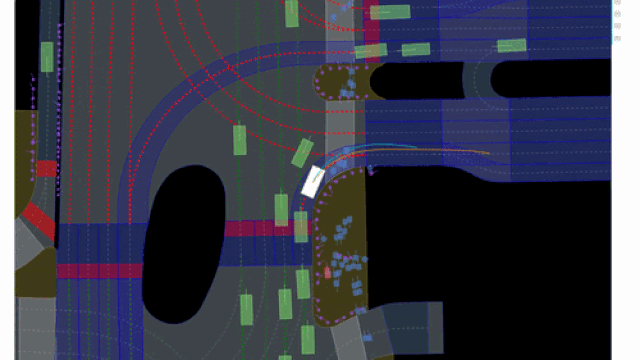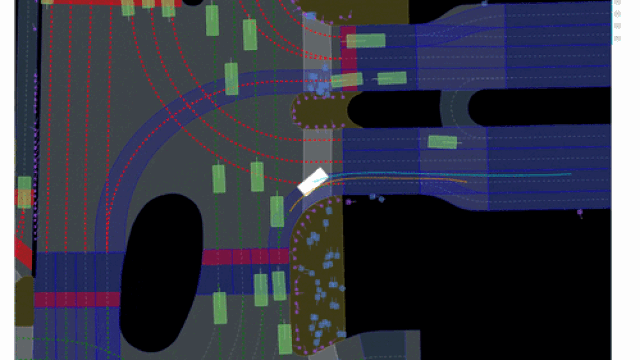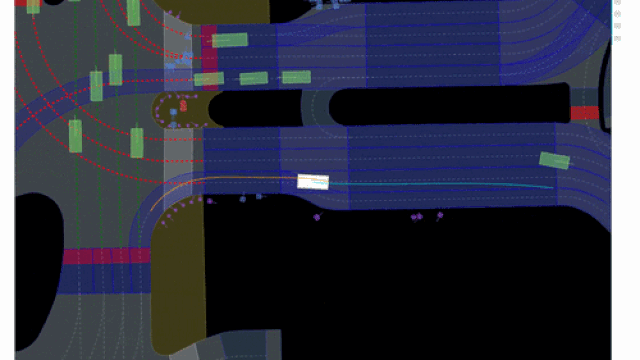
Zebin Xing*, Xingyu Zhang*, Yang Hu, Bo Jiang, Tong He, Qian Zhang, Xiaoxiao Long, Wei Yin† CVPR, 2025 [arXiv] [Homepage] [Code] 
A goal-driven flow matching approach that constrains multimodal trajectory generation through scene-aware goal scoring for efficient flow matching-based planning. |
|
Yupeng Zheng*, Zebin Xing*, Qichao Zhang†, Bu Jin, Pengfei Li, Yuhang Zheng, Zhongpu Xia, Kun Zhan, Xianpeng Lang, Yaran Chen, Dongbin Zhao TCDS, 2025 [arXiv] [Code] 
The first multi-modal large language model agent for closed-loop planning that introduces hierarchical reasoning and self-reflection into autonomous driving systems. |
|
|
|
|
|
Outside of research, I enjoy taking walks in the park, binge-watching TV shows, and swimming. |
|
Website template from Jon Barron. |